Live · SSD MobileNetV2 · FastAPI stream
Systems that see, think and move.
R&D AI roboticist and automation engineer at Baliyo Ventures. I turn computer-vision research into reliable, physical-world automation, one perception loop at a time.
- 01 Perception OpenCV · PyTorch · SSD
- 02 Edge compute Jetson Nano · Lidar
- 03 Actuation Embedded control
27.7172° N 85.3240° E Portfolio — Vol. 03 / 2026
- Computer vision
- Edge intelligence
- Automation
- Backend systems
- Embedded hardware
01 Profile
Curiosity, made tangible.
I work at the intersection of intelligent software and the physical world — building systems that are perceptive, connected, and ready for action beyond the notebook.
As a junior R&D AI roboticist at Baliyo Ventures, I explore computer vision, edge devices, and spatial intelligence. BSc Hons in Computing with AI, Islington College (2025), plus internships at Ants Pvt. Ltd. and Atreya Software Solutions.
build with intent. learn in public. ship what matters.
- 06 Selected projects
- 2025 BSc (Hons) Computing with AI
- KTM Based in Kathmandu, Nepal
02 Selected work
From signal to solution.
Perception, edge compute and embedded systems — each project starts with a physical-world constraint and ends with something that runs.
More projects
-
Uses machine learning regression to find patterns in weather data and produce informed meteorological predictions. Converts historical measurements into a practical forecasting workflow with interpretable model experimentation.
-
Transforms workforce data into clearer salary insights through careful data processing and analytical exploration. Makes compensation patterns easier to inspect, compare, and use in workforce decision-making.
-
Connects hardware and software into a responsive interactive display that makes robotic behavior visible and engaging. Creates a tangible interface for demonstrating intelligent behavior beyond a screen or simulation.
-
An embedded, wireless response system designed to make quiz participation immediate, fair, and easy to operate. Replaces tangled manual signaling with a reliable hardware workflow for real-time group interaction.
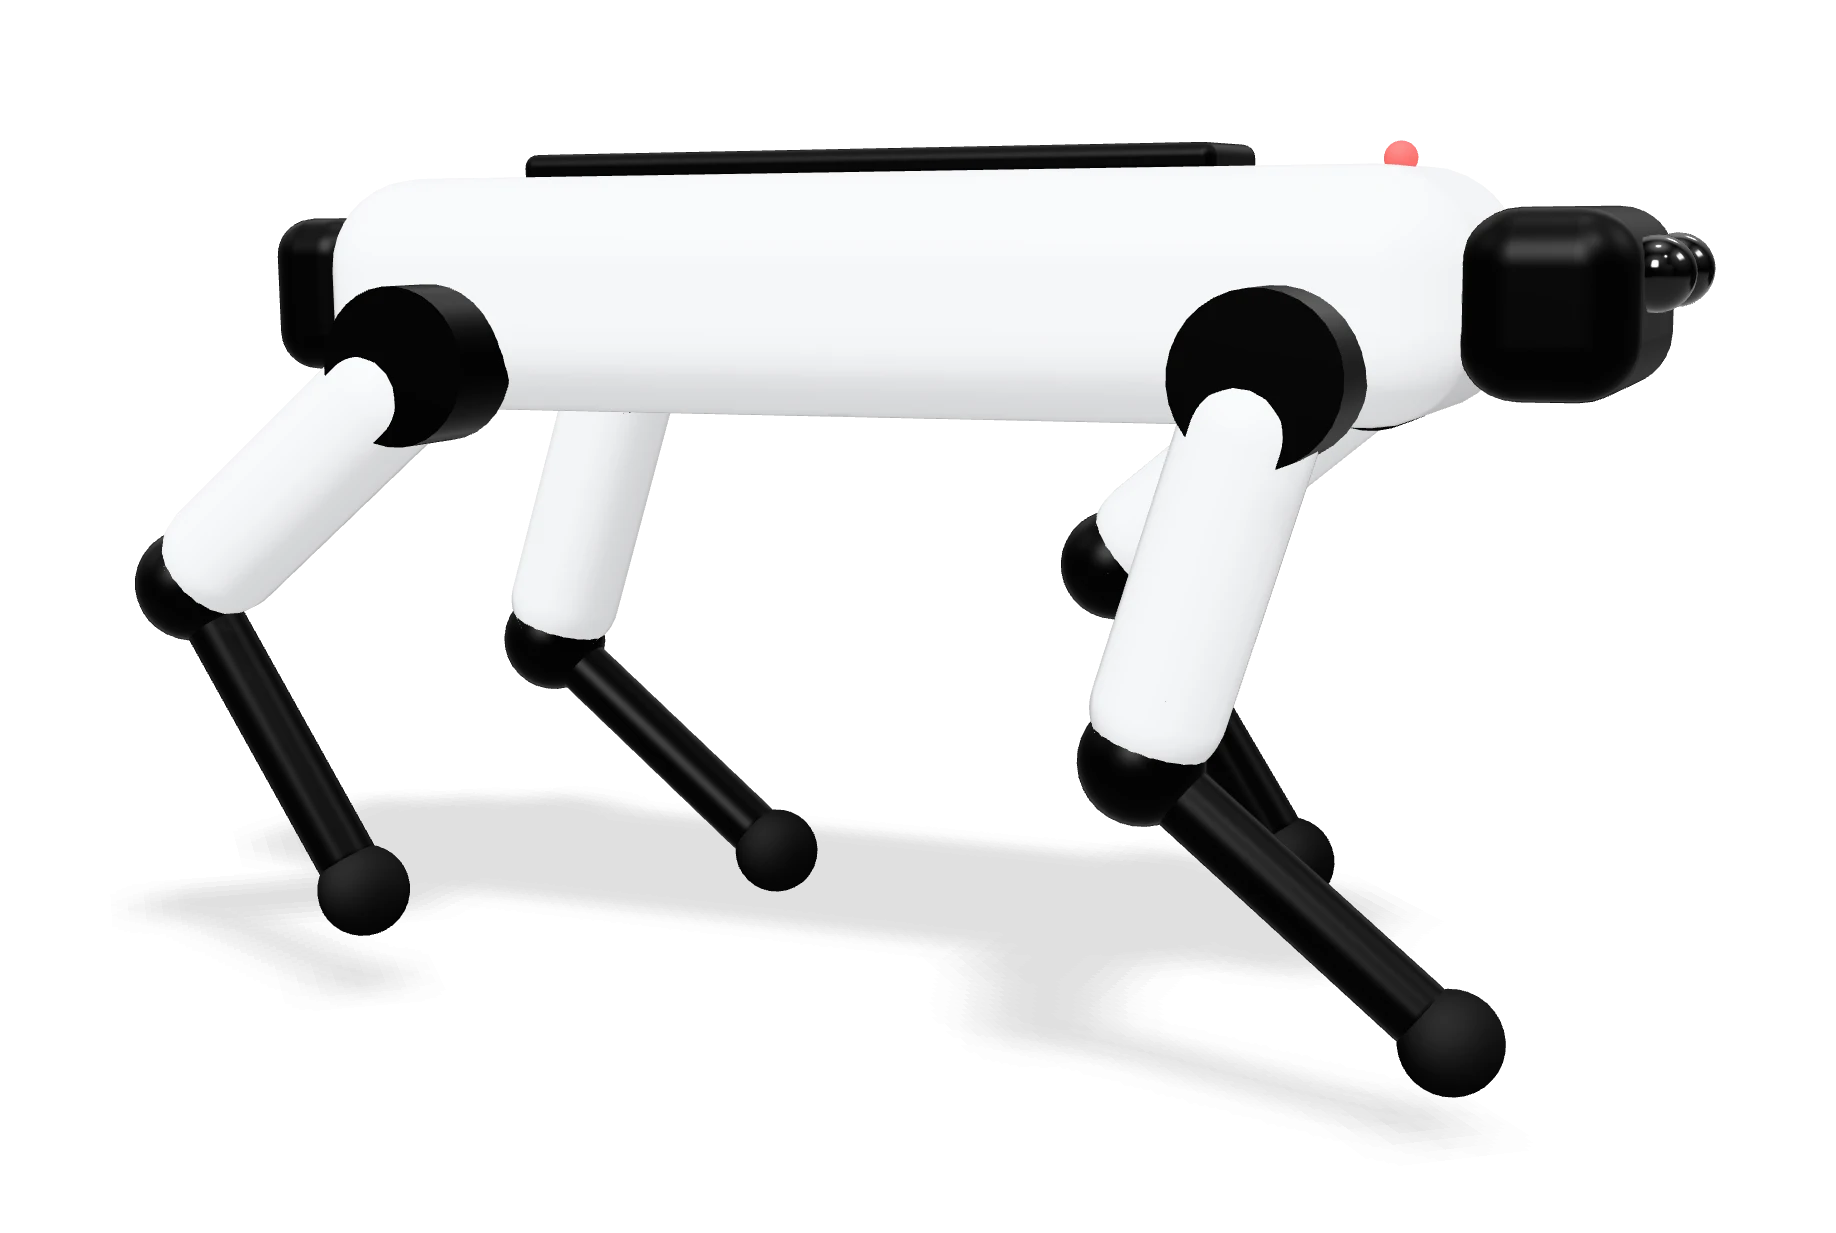
Interlude — Fig. 04 Gait study
Locomotion is a perception problem first.
03 Services & stack
A practical stack.
I take a problem from sensor to service: perceive it, model it, ship it to hardware, and expose it through an API someone else can use.
-
(A)
Perception & computer vision
Detection, depth and spatial reasoning that turns pixels into decisions a machine can act on.
- PyTorch
- OpenCV
- SSD MobileNetV2
- Lidar fusion
-
(B)
Edge & embedded systems
Models squeezed onto real hardware, where latency, power and memory shape the design.
- Jetson Nano
- Microcontrollers
- Linux · SSH
- Edge integration
-
(C)
Backend & architecture
Services that expose robotic capability cleanly — typed APIs, containers, and sane boundaries.
- Python · FastAPI
- Java · Spring Boot
- REST · Microservices
- Docker · AWS · Azure
-
(D)
Data & analytics
Turning raw logs and datasets into models and charts that hold up to questions.
- scikit-learn
- Pandas · NumPy
- Regression
- Matplotlib · Seaborn
04 Experience
Learning by shipping.
-
2025 — Now
R&D AI Roboticist
Baliyo Ventures
Exploring computer vision, edge devices, spatial intelligence, and practical robotic systems.
-
2025
BSc (Hons) Computing with AI
Islington College
Built a foundation across artificial intelligence, software engineering, data, and systems.
-
Earlier
Engineering internships
Ants Pvt. Ltd. · Atreya Software Solutions
Learned to move from coursework into team workflows, implementation, and delivery.
Also: Club Tamer for Leo Club of Temple Peace (2021–2022) — where I learned to turn shared energy into organized action.
05 Field notes
Work in progress.
Perception is only useful when it changes a decision.
The next layer after detection is context: what should the system do with what it sees?
Edge systems make constraints visible.
Latency, power, memory, and deployment shape the model as much as the dataset does.
Build the smallest loop that can teach you something.
Hardware and software become clearer when the first experiment is close to reality.
06 Contact
Have a difficult problem?
Let’s talk about what you’re building, what’s stuck, and where intelligent systems could take it next.
- GitHub
- NotAScratch
- in/samirsen8
- Location
- Kathmandu, NP
- Local time
- UTC +5:45